 Rockin' Robos
Our Robot
Engineered for precision, speed, and reliability.
Engineering Process
Our robot is the result of hundreds of hours of design, prototyping, CAD modeling, and testing. We utilize advanced manufacturing techniques like custom 3D printing and CNC routing alongside standard FTC components to create a highly competitive machine.
Hardware Specifications
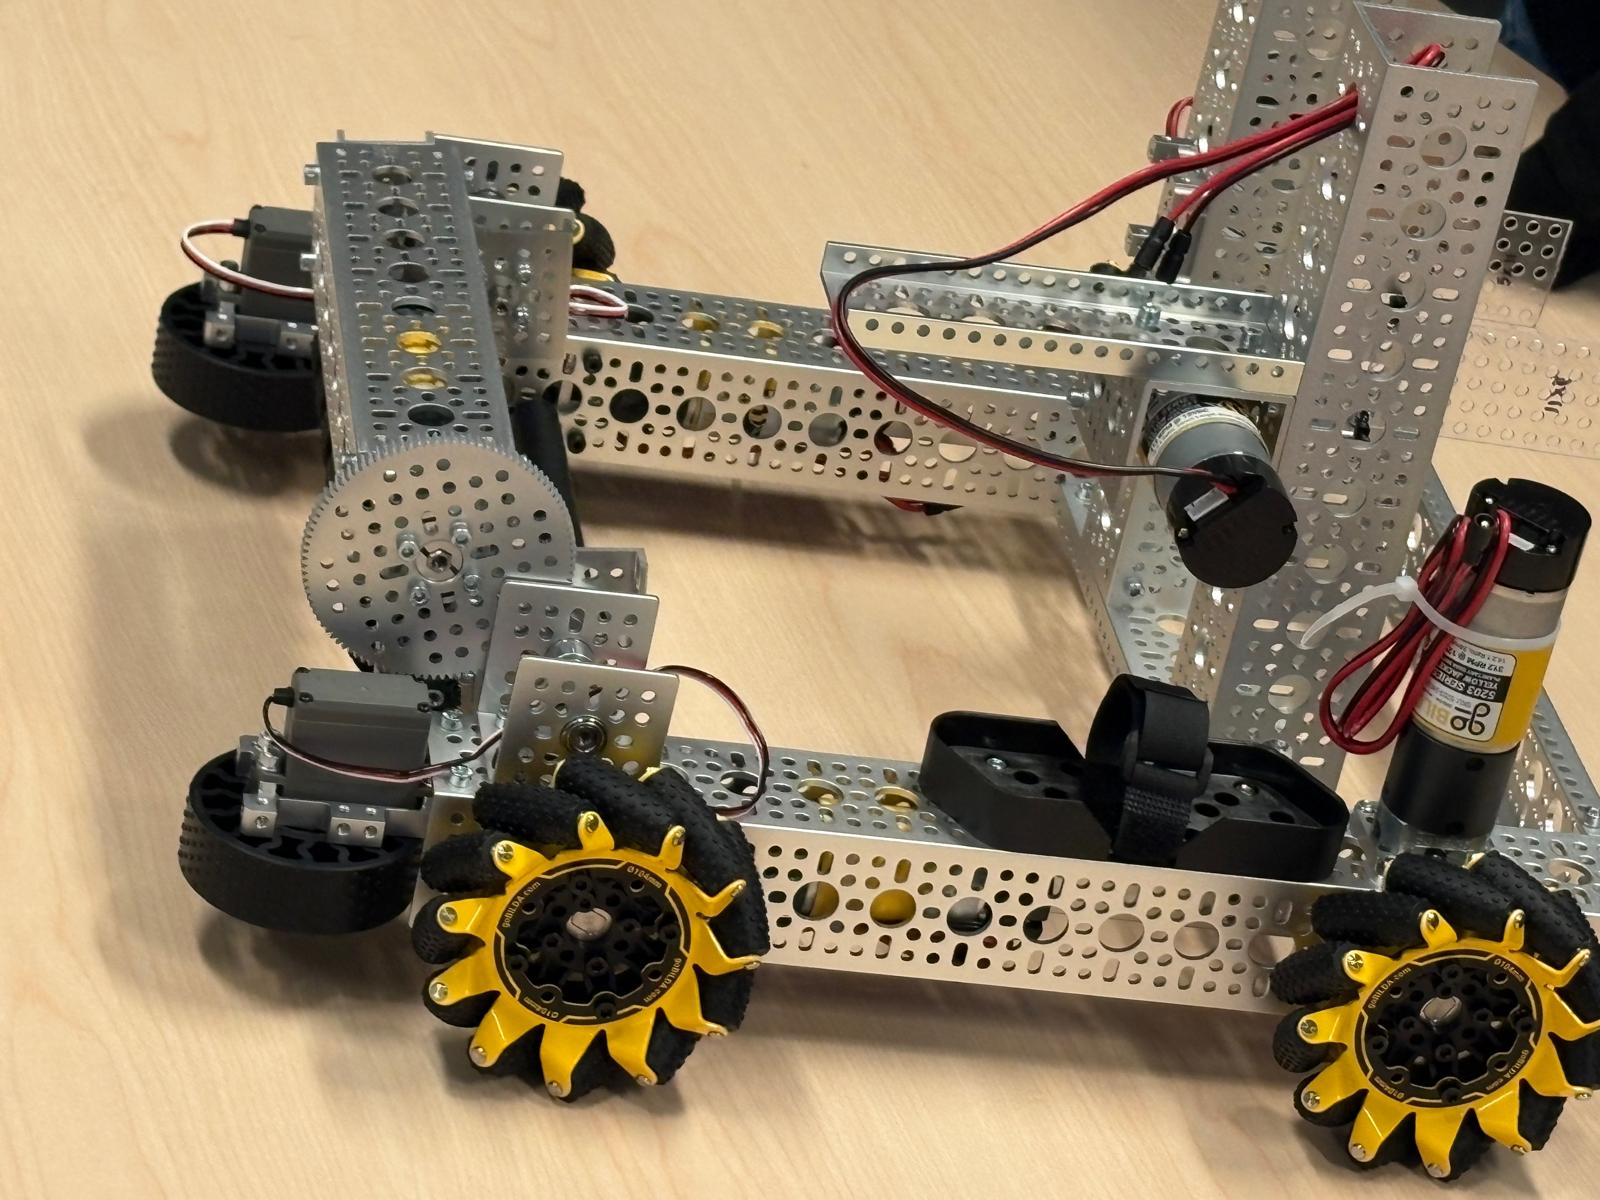
Mecanum Drivetrain
Custom-geared mecanum drive allows for rapid strafing and agile field navigation. Powered by four high-torque motors for maximum pushing power and speed.
Active Intake
Compliant wheels driven by high-speed servos ensure quick and reliable collection of game elements from any angle.
Linear Elevator
A multi-stage rigged linear slide system reaches maximum height in under 1.5 seconds, utilizing constant force springs to offset the payload weight.
Custom 3D Printed Parts
Over 30% of our mechanisms incorporate custom-designed, 3D-printed PETG components for lightweight strength and modularity.
Software & Autonomous
Software brings the hardware to life. Our programming team utilizes Java with advanced control algorithms to ensure consistency and high scoring potential in every match.
- Dead-Wheel Odometry: Three unpowered tracking wheels provide millimeter-accurate localization on the field, entirely independent of wheel slip.
- Computer Vision: OpenCV pipelines dynamically detect randomized game elements during the autonomous period, calculating optimal routes on the fly.
- PIDF Control: We utilize Proportional-Integral-Derivative plus Feedforward loops on our lifting mechanisms and drivetrain for smooth, exact positioning.